Shutong JIN
Hi! I am a fourth-year PhD student in robotic manipulation at KTH Royal Institute of Technology, advised by Prof. Florian Pokorny and Prof. Erik Elmroth. I was a visiting PhD student at UC Berkeley's AUTOLab, advised by Prof. Ken Goldberg. Previously, I completed my Master’s degree in Computer Control and Automation at Nanyang Technological University. I received my Bachelor’s degree in Electrical and Electronics Engineering from Wuhan University, with a double degree in Robotics from École Centrale. My research is funded by the Wallenberg AI, Autonomous Systems and Software Program (WASP).
Recent News
- [2026-06] One paper accepted for IROS 2026.
- [2026-03] I joined AUTOLab, UC Berkeley.
- [2026-03] One paper recently accepted for IEEE Transactions on Multimedia.
- [2026-01] We are pleased to announce the workshop on Connected Robotic Autonomous System at ICRA 2026.
- [2026-01] Keynote talk at the WASP Winter Conference 2026.
- [2026-01] One paper accepted for ICRA 2026.
Research
My research spans three threads focused on compositional data curation:
- Understanding how dataset composition and properties influence robot policies performance through real-world case studies at scale.
- Curating additional data to mitigate observed policy performance drops via targeted real-world collection and generative modeling.
- Scaling data curation through parallelization in the cloud.
Research Keywords: Robotic Manipulation, Compositional Data Curation, Cloud Robotics.
Academic Service
- Teaching: DD2424 Deep Learning in Data Science, DD1420 Foundations of Machine Learning.
- Workshop Organization: RoDGE, IROS 2025 Workshop; CloudGripper, CoRL 2026 Demo; Connected-Robots, ICRA 2026 Workshop.
- Reviewing Activities: RSS, CoRL, ICRA, IROS, CASE, RA-L, CVPR, ICCV ECCV, WACV.
- Supervised Master's Students: Axel Kaliff, Ben Temming, Jin Yang, Pranish Kumar Munnangi.
Publications
|
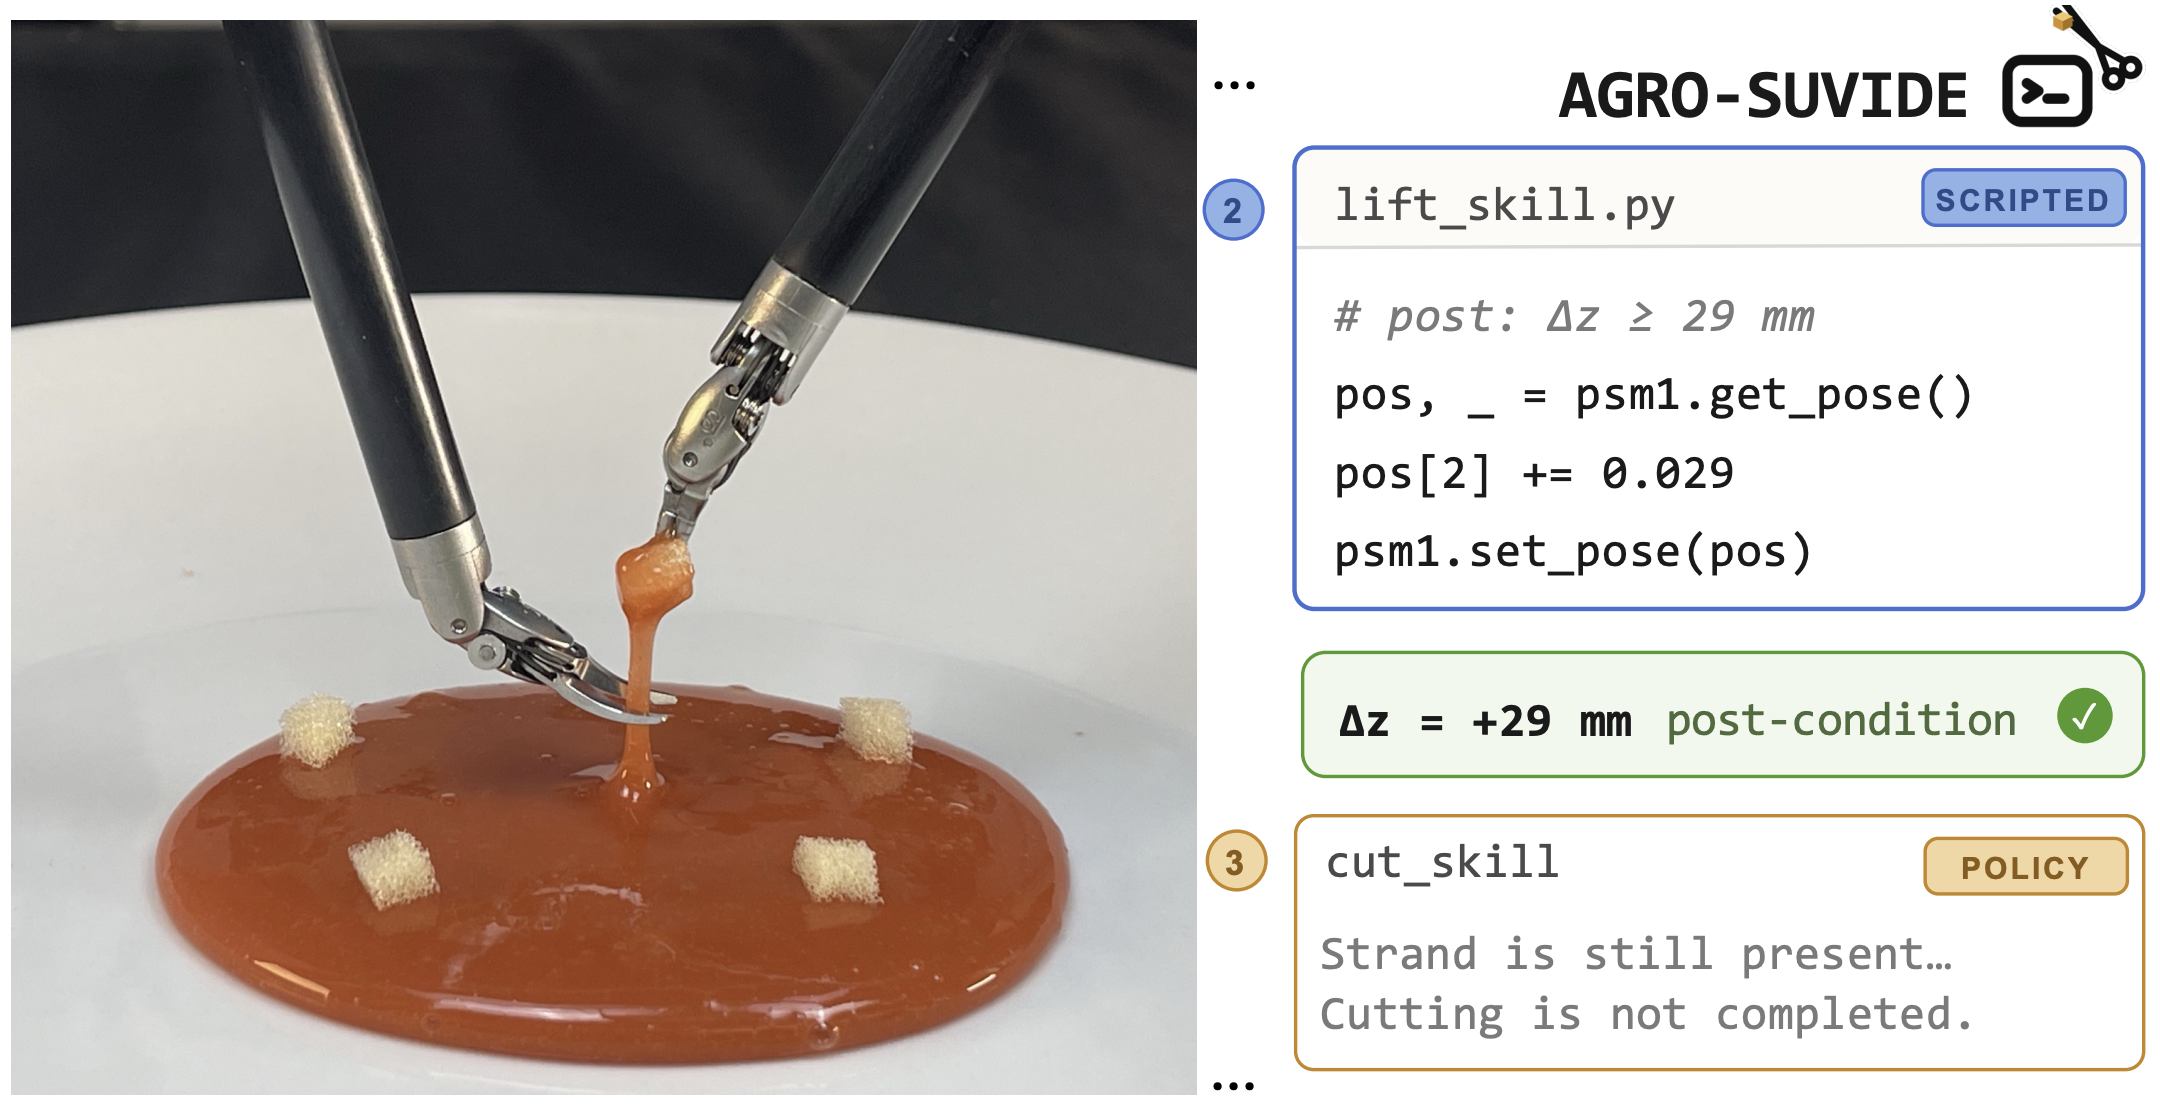
AGRO-SUVIDE: Agentic Robotics for Surgical Viscoelastic Debridement [Link] Shutong Jin, Ziyang Chen, Preethi Satish, Meadow Shen, Gary Guthart, Florian T. Pokorny and Ken Goldberg Preprint
|
|
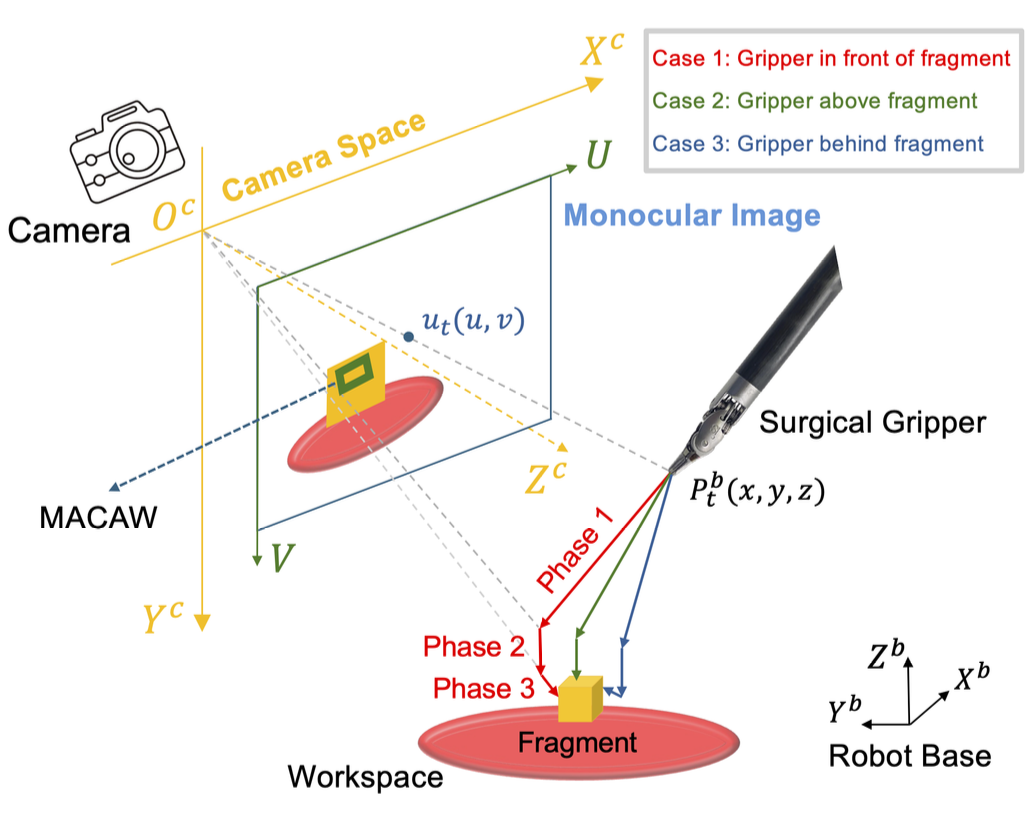
MACAW: Reliable And Efficient Surgical Debridement Using Monocular Adaptive Compact Attention Windows [Link] Ziyang Chen, Shutong Jin, Preethi Satish, Sareena Mann, Cael Magner, Danyal Fer, Omid Mohareri, Gary Guthart and Ken Goldberg Preprint
|
|
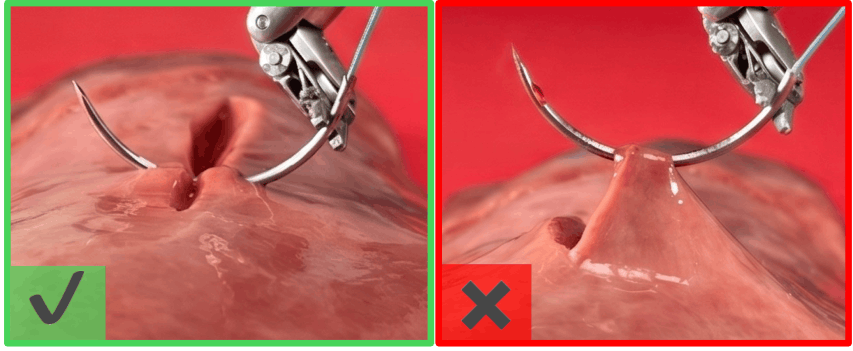
Adversarial Vulnerabilities of Learned Telesurgery Policies [Link] Shutong Jin, Ziyang Chen, Preethi Satish, Paavan Gupta, Florian T. Pokorny and Ken Goldberg Preprint
|
|
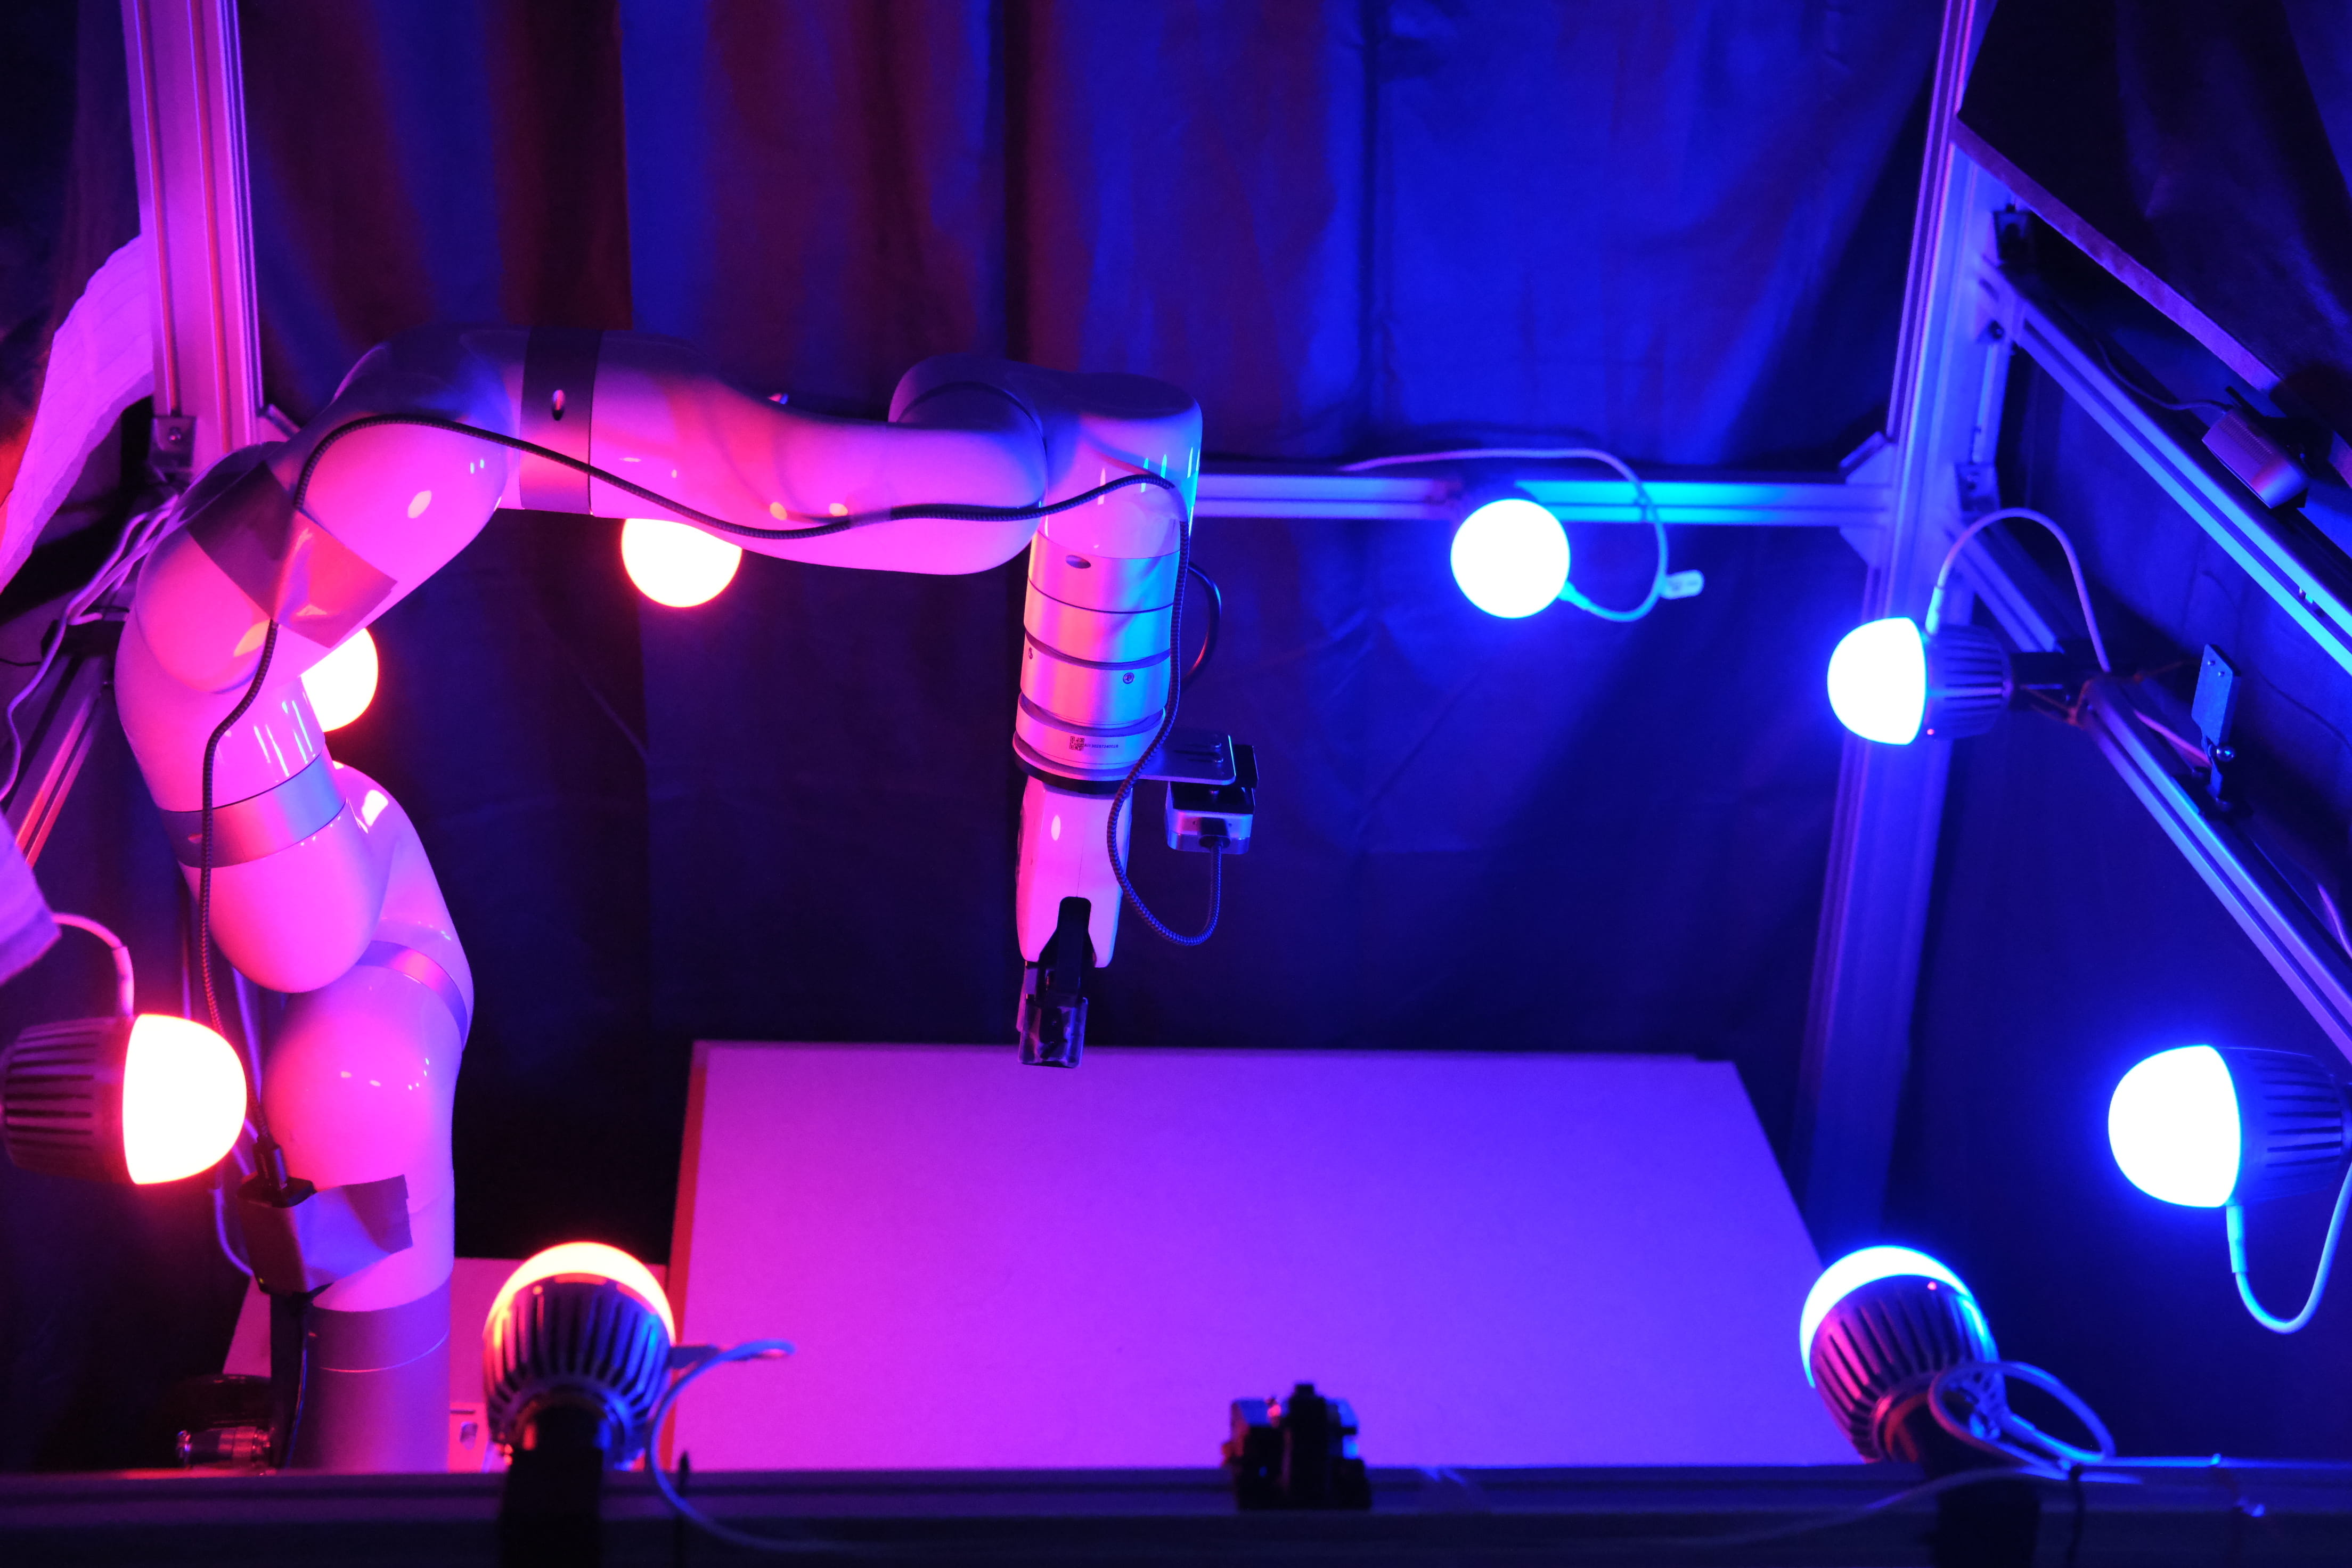
RoboLight: A Dataset with Linearly Composable Illumination for Robotic Manipulation [Link] Shutong Jin*, Jin Yang*, Muhammad Zahid and Florian T. Pokorny 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS).
|
|
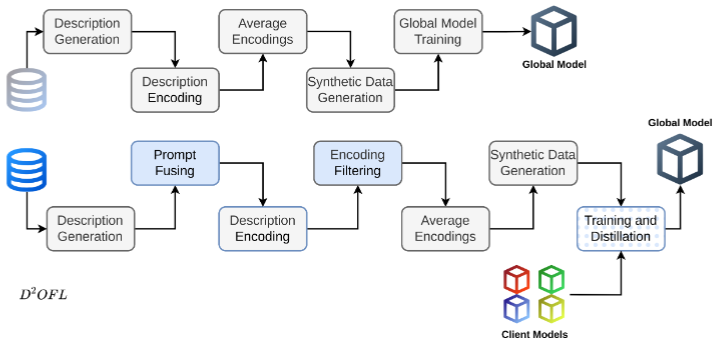
D2OFL: Distillation-Enhanced Diffusion Model Assisted One-Shot Federated Learning Obaidullah Zaland, Shutong Jin, Florian T. Pokorny and Monowar Bhuyan IEEE Transactions on Multimedia 2026.
|
|
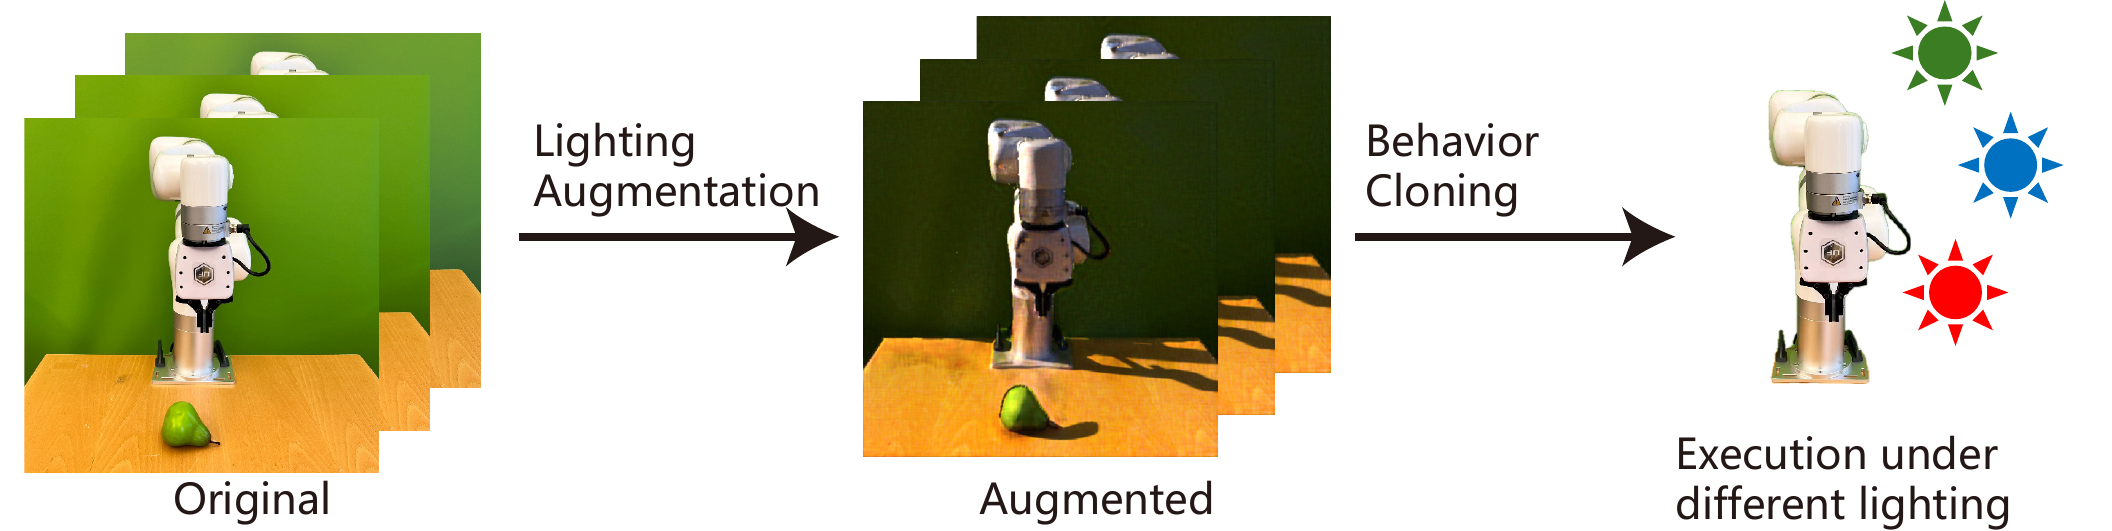
Physically-based Lighting Generation for Robotic Manipulation [Link] Shutong Jin*, Lezhong Wang*, Ben Temming and Florian T. Pokorny 2026 IEEE International Conference on Robotics & Automation (ICRA)
|
|
R900: An Analysis of the Cost-Effectiveness of Random Exploration based on 900 Hours of Robotic Stacking [Link] Shutong Jin*, Axel Kaliff*, Ruiyu Wang, Muhammad Zahid and Florian T. Pokorny Preprint
|
|
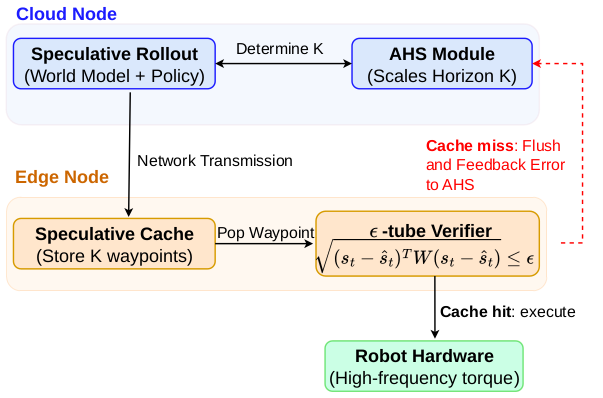
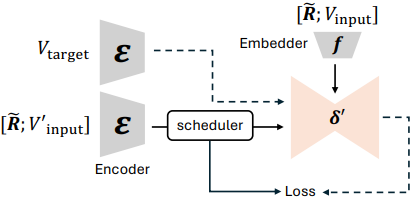
Speculative Policy Orchestration: A Latency-Resilient Framework for Cloud-Robotic Manipulation Chanh Nguyen*, Shutong Jin*, Florian T. Pokorny and Erik Elmroth Preprint
|
|
ReLumix: Extending Image Relighting to Video via Video Diffusion Models [Link] Lezhong Wang, Shutong Jin, Ruiqi Cui, Anders Bjorholm Dahl, Jeppe Revall Frisvad and Siavash Bigdeli Preprint
|
|
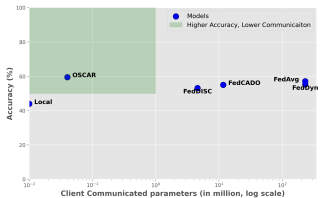
One-Shot Federated Learning with Classifier-Free Diffusion Models [Link] Obaidullah Zaland*, Shutong Jin*, Florian T. Pokorny and Monowar Bhuyan IEEE International Conference on Multimedia & Expo (ICME) 2025
|
|
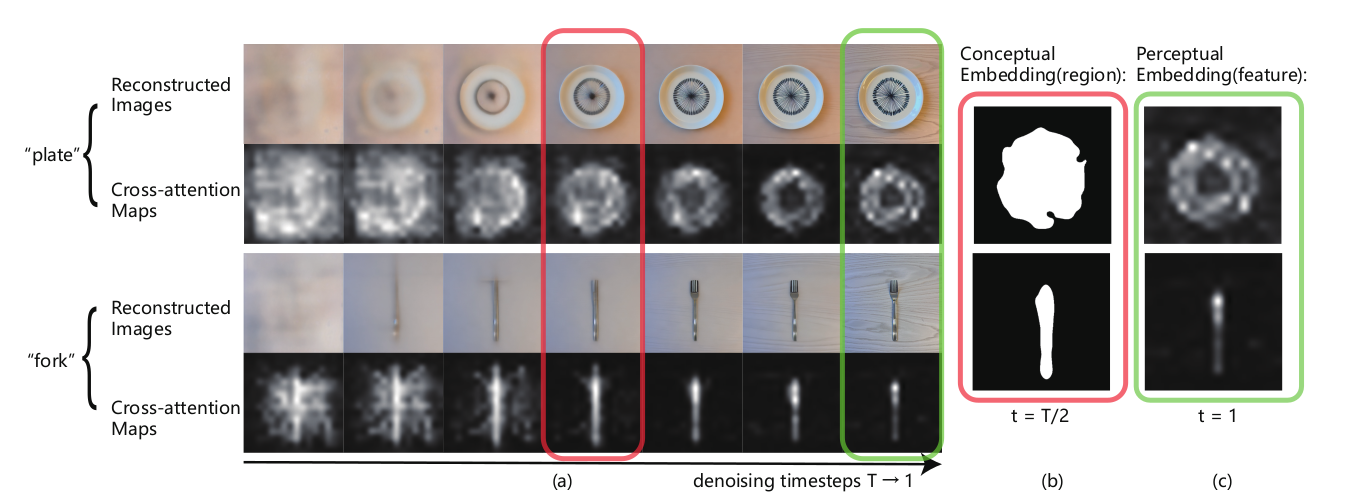
PACA: Perspective-Aware Cross-Attention Representation for Zero-Shot Scene Rearrangement [Link] Shutong Jin*, Ruiyu Wang*, Kuangyi Chen and Florian T. Pokorny Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision (WACV), 2025
|
|
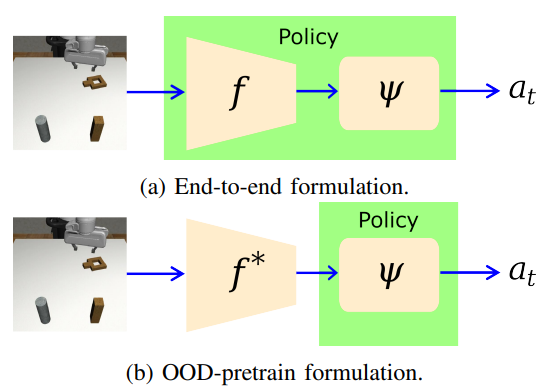
Feature Extractor or Decision Maker: Rethinking the Role of Visual Encoders in Visuomotor Policies [Link] Ruiyu Wang, Zheyu Zhuang, Shutong Jin, Nils Ingelhag, Danica Kragic and Florian T. Pokorny 2025 IEEE International Conference on Robotics & Automation (ICRA).
|
|
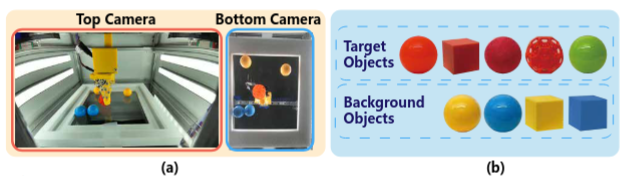
CloudGripper-Push-1K: Understanding the Generalization Gap of Physics and Background Attributes for Robotic Manipulation Shutong Jin, Ruiyu Wang, Muhammad Zahid and Florian T. Pokorny IEEE/RSJ IROS 2024 Workshop on Collecting, Managing, and Utilizing Data through Embodied Robots.
Best Poster Award |
|
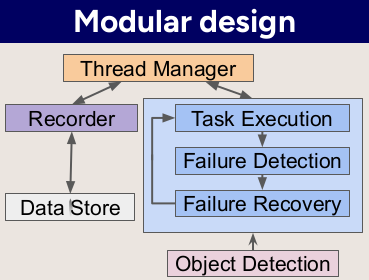
CloudGripper-AutoGrasper: A Cloud Robotics Toolkit for Automatic Data Collection Axel Kaliff, Shutong Jin, Muhammad Zahid and Florian T. Pokorny IEEE/RSJ IROS 2024 Workshop on Collecting, Managing, and Utilizing Data through Embodied Robots.
|
|
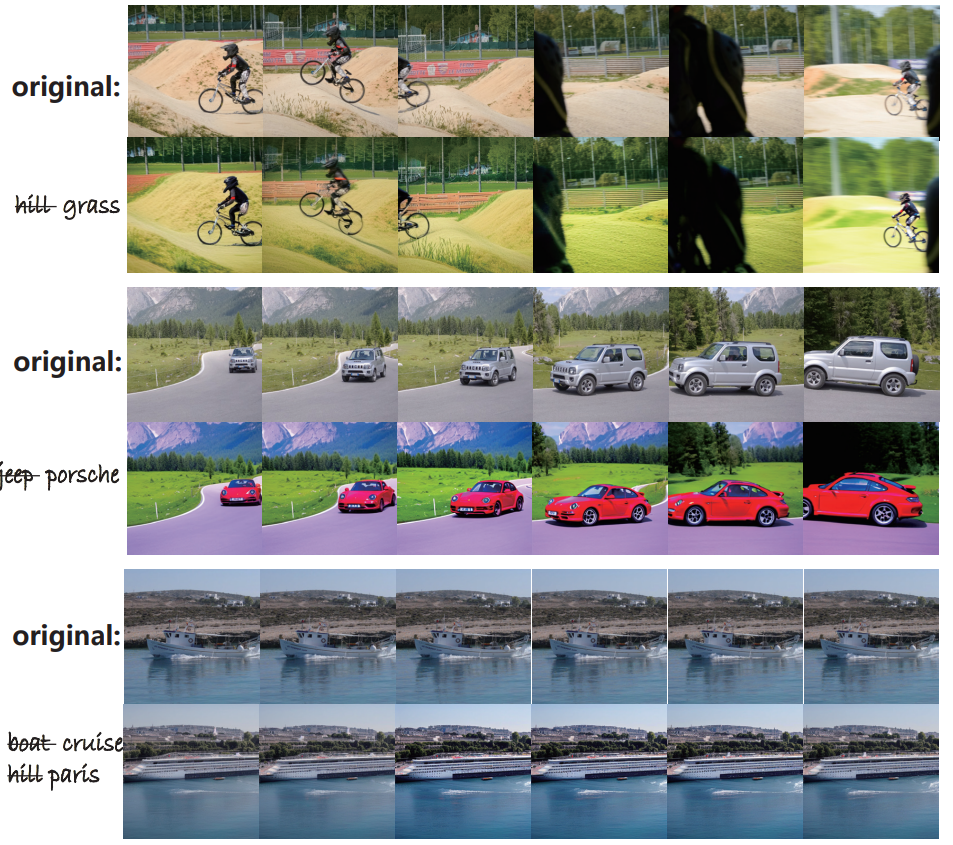
RealCraft: Attention Control as A Tool for Zero-shot Consistent Video Editing [Link] Shutong Jin, Ruiyu Wang and Florian T. Pokorny 32nd International Conference on Neural Information Processing.
|
|
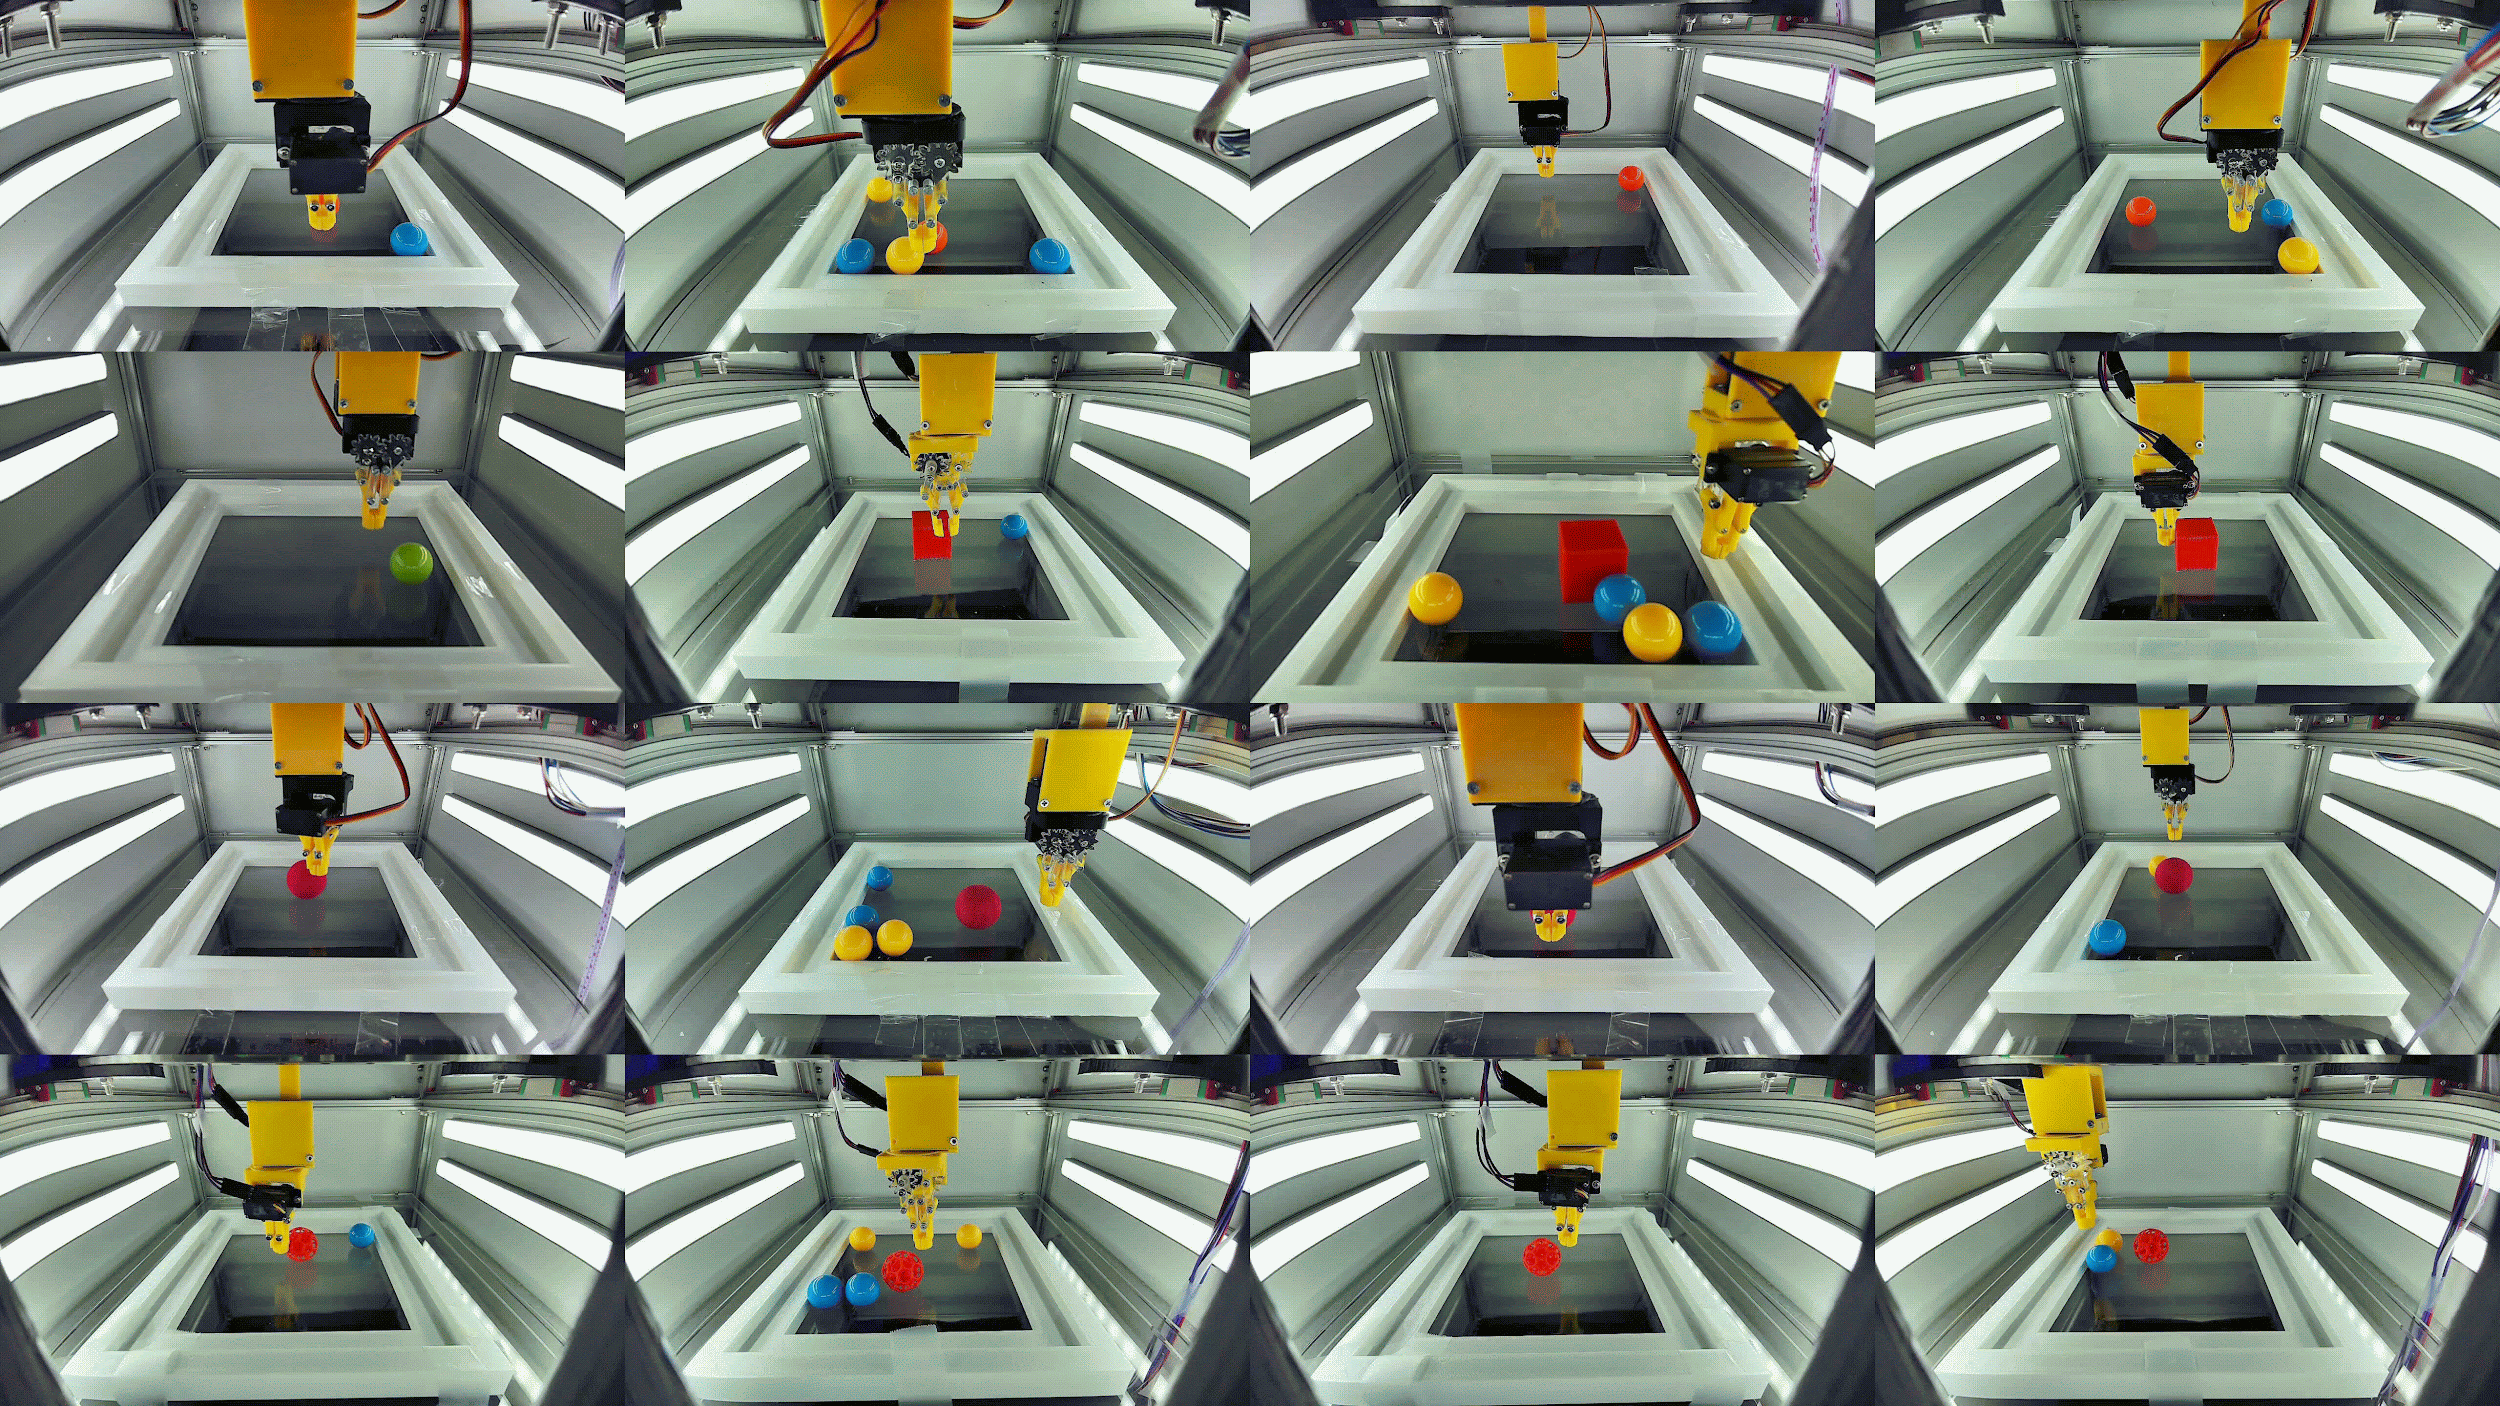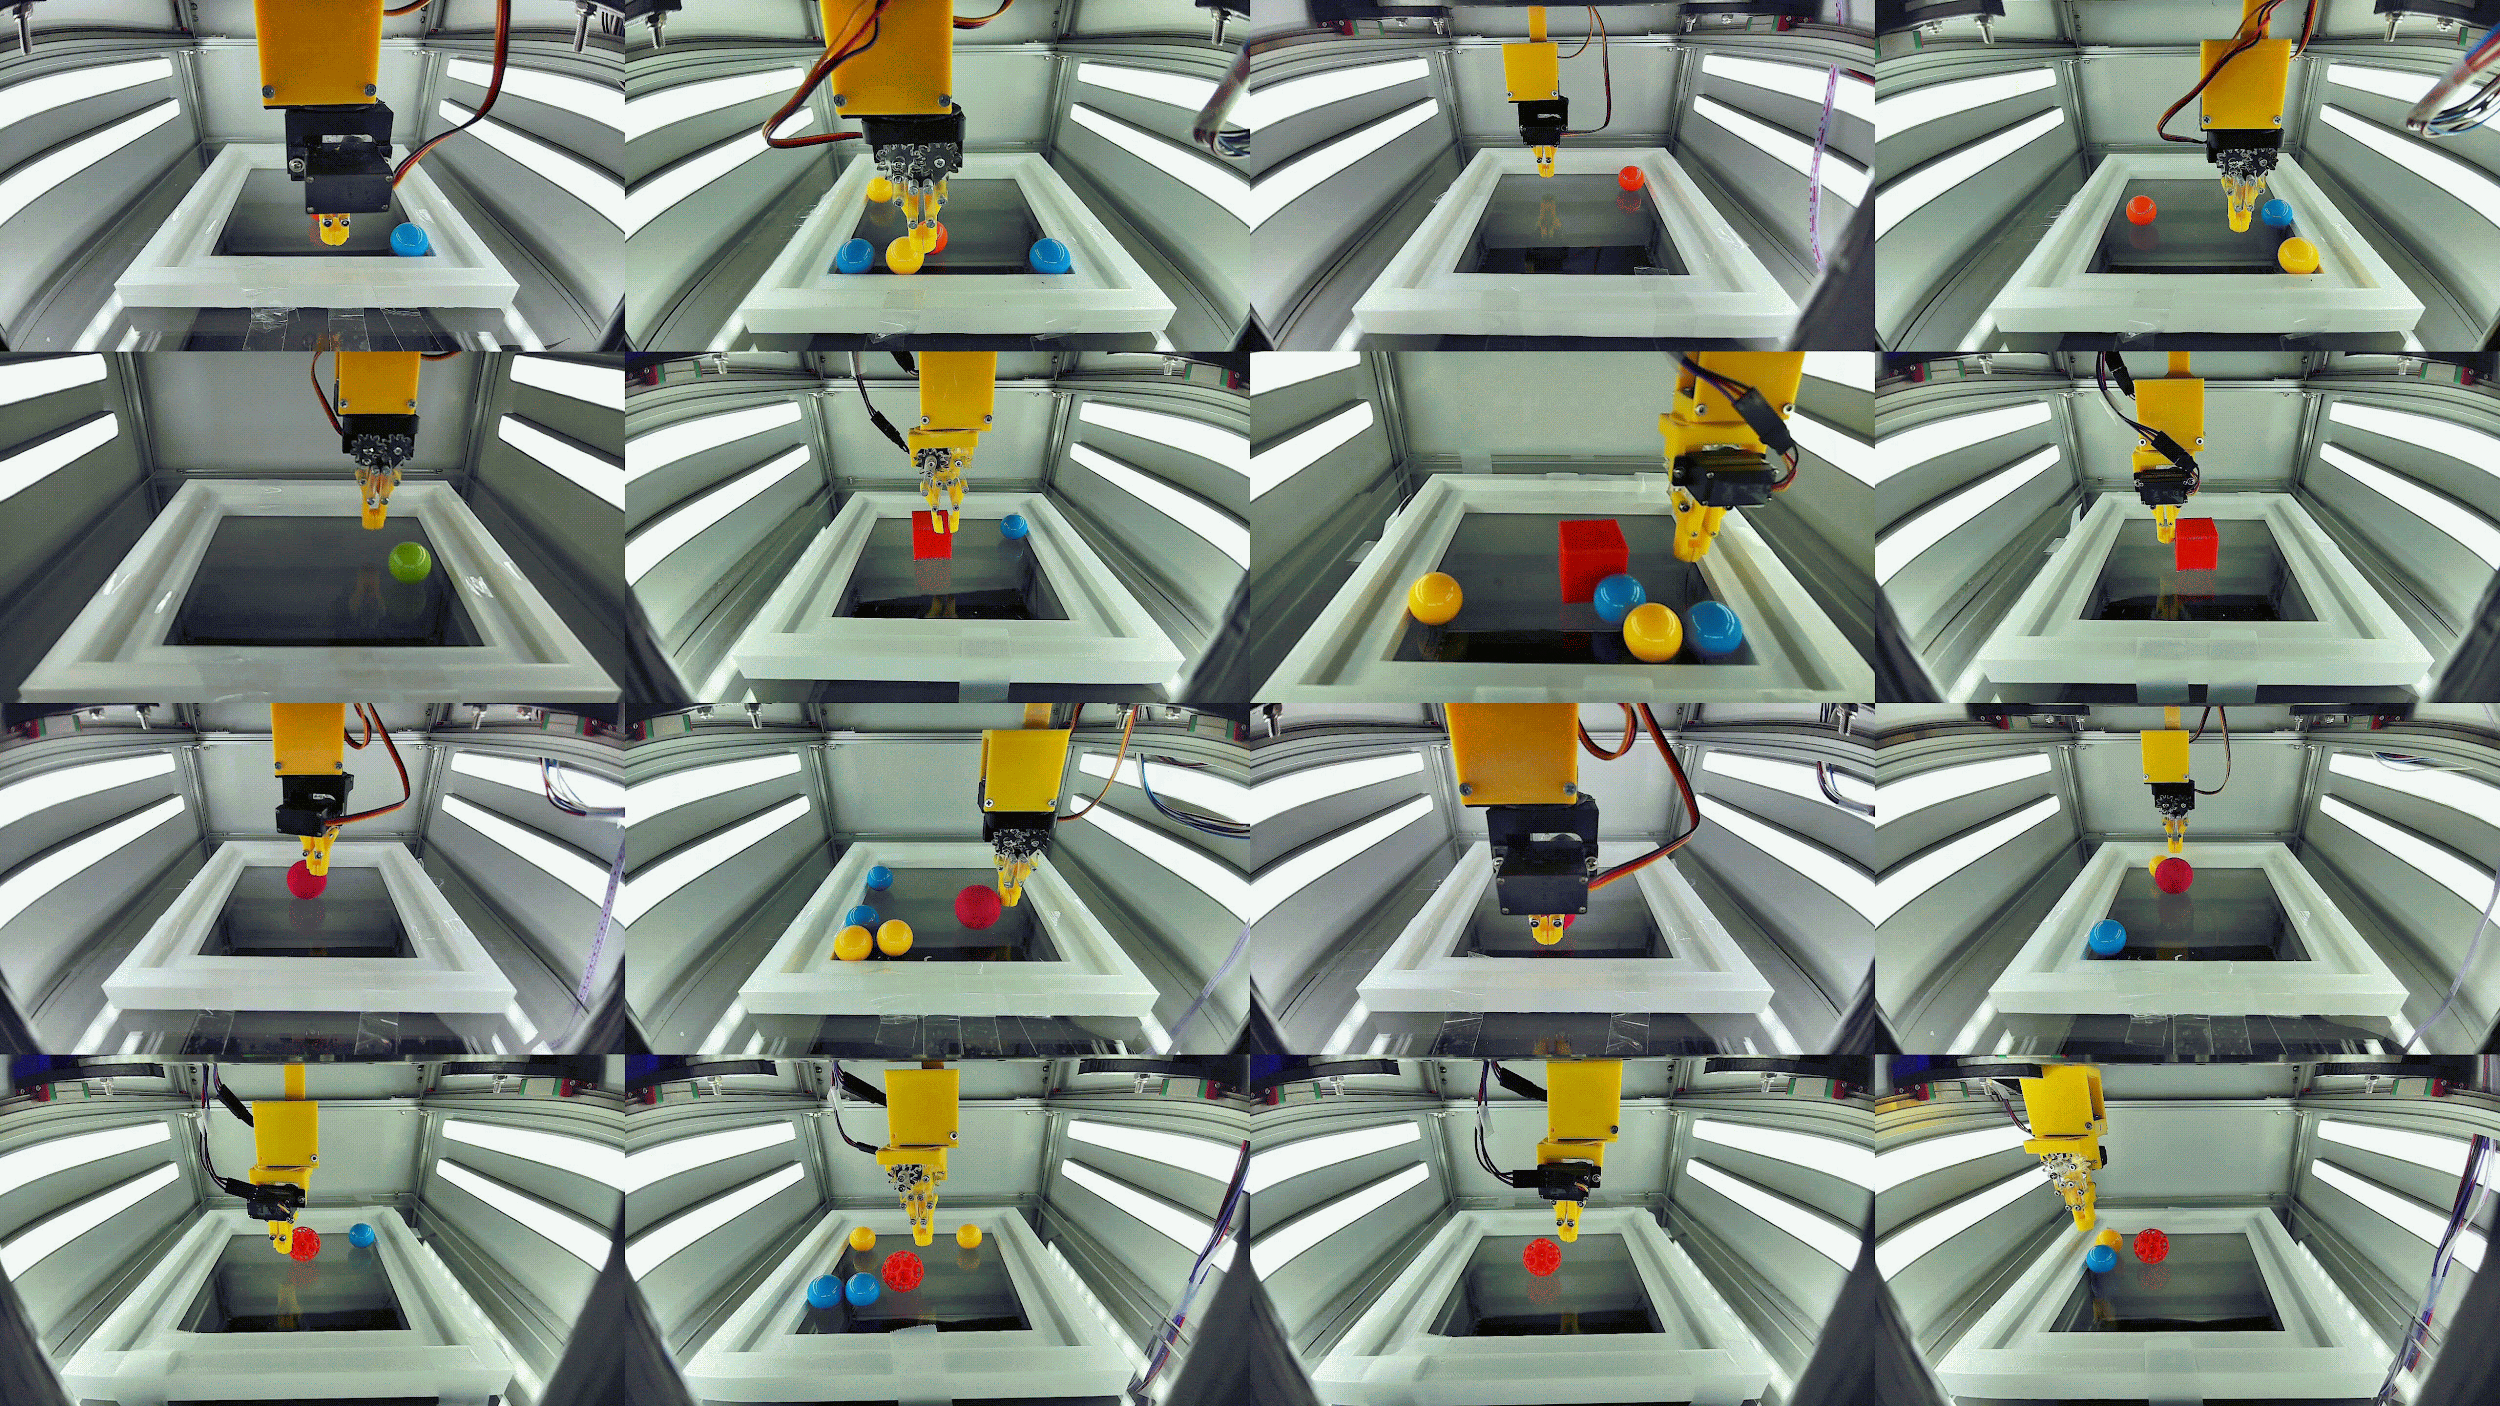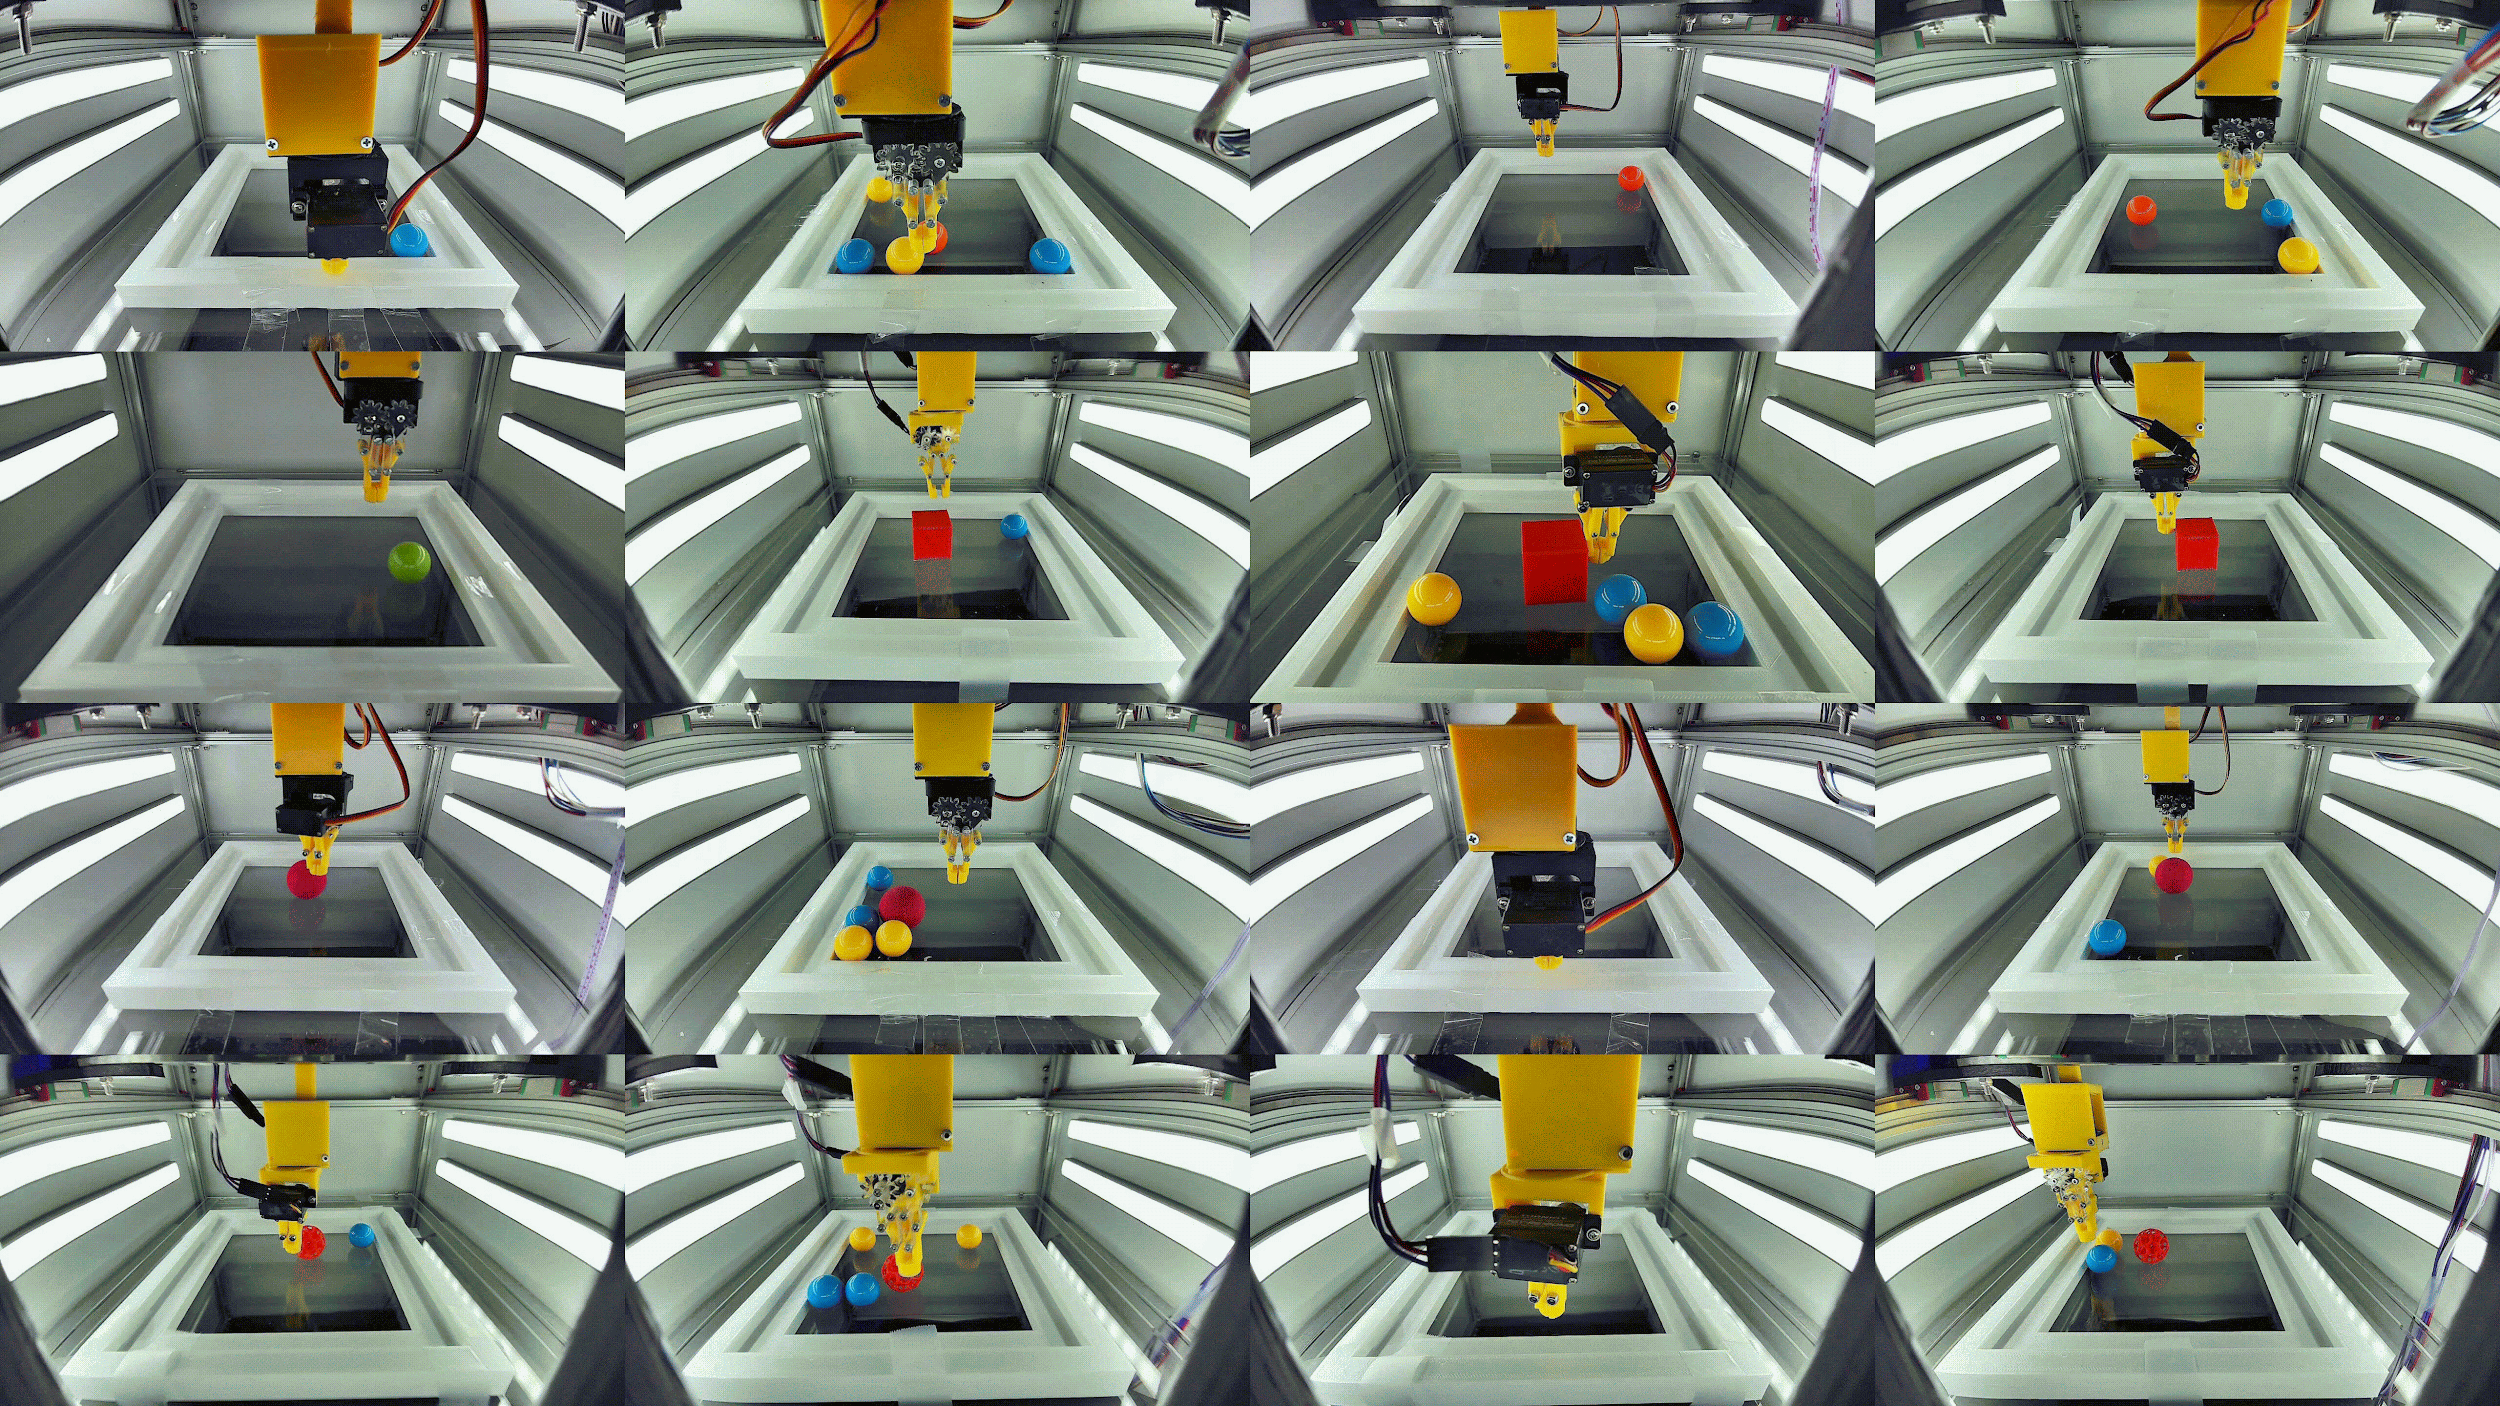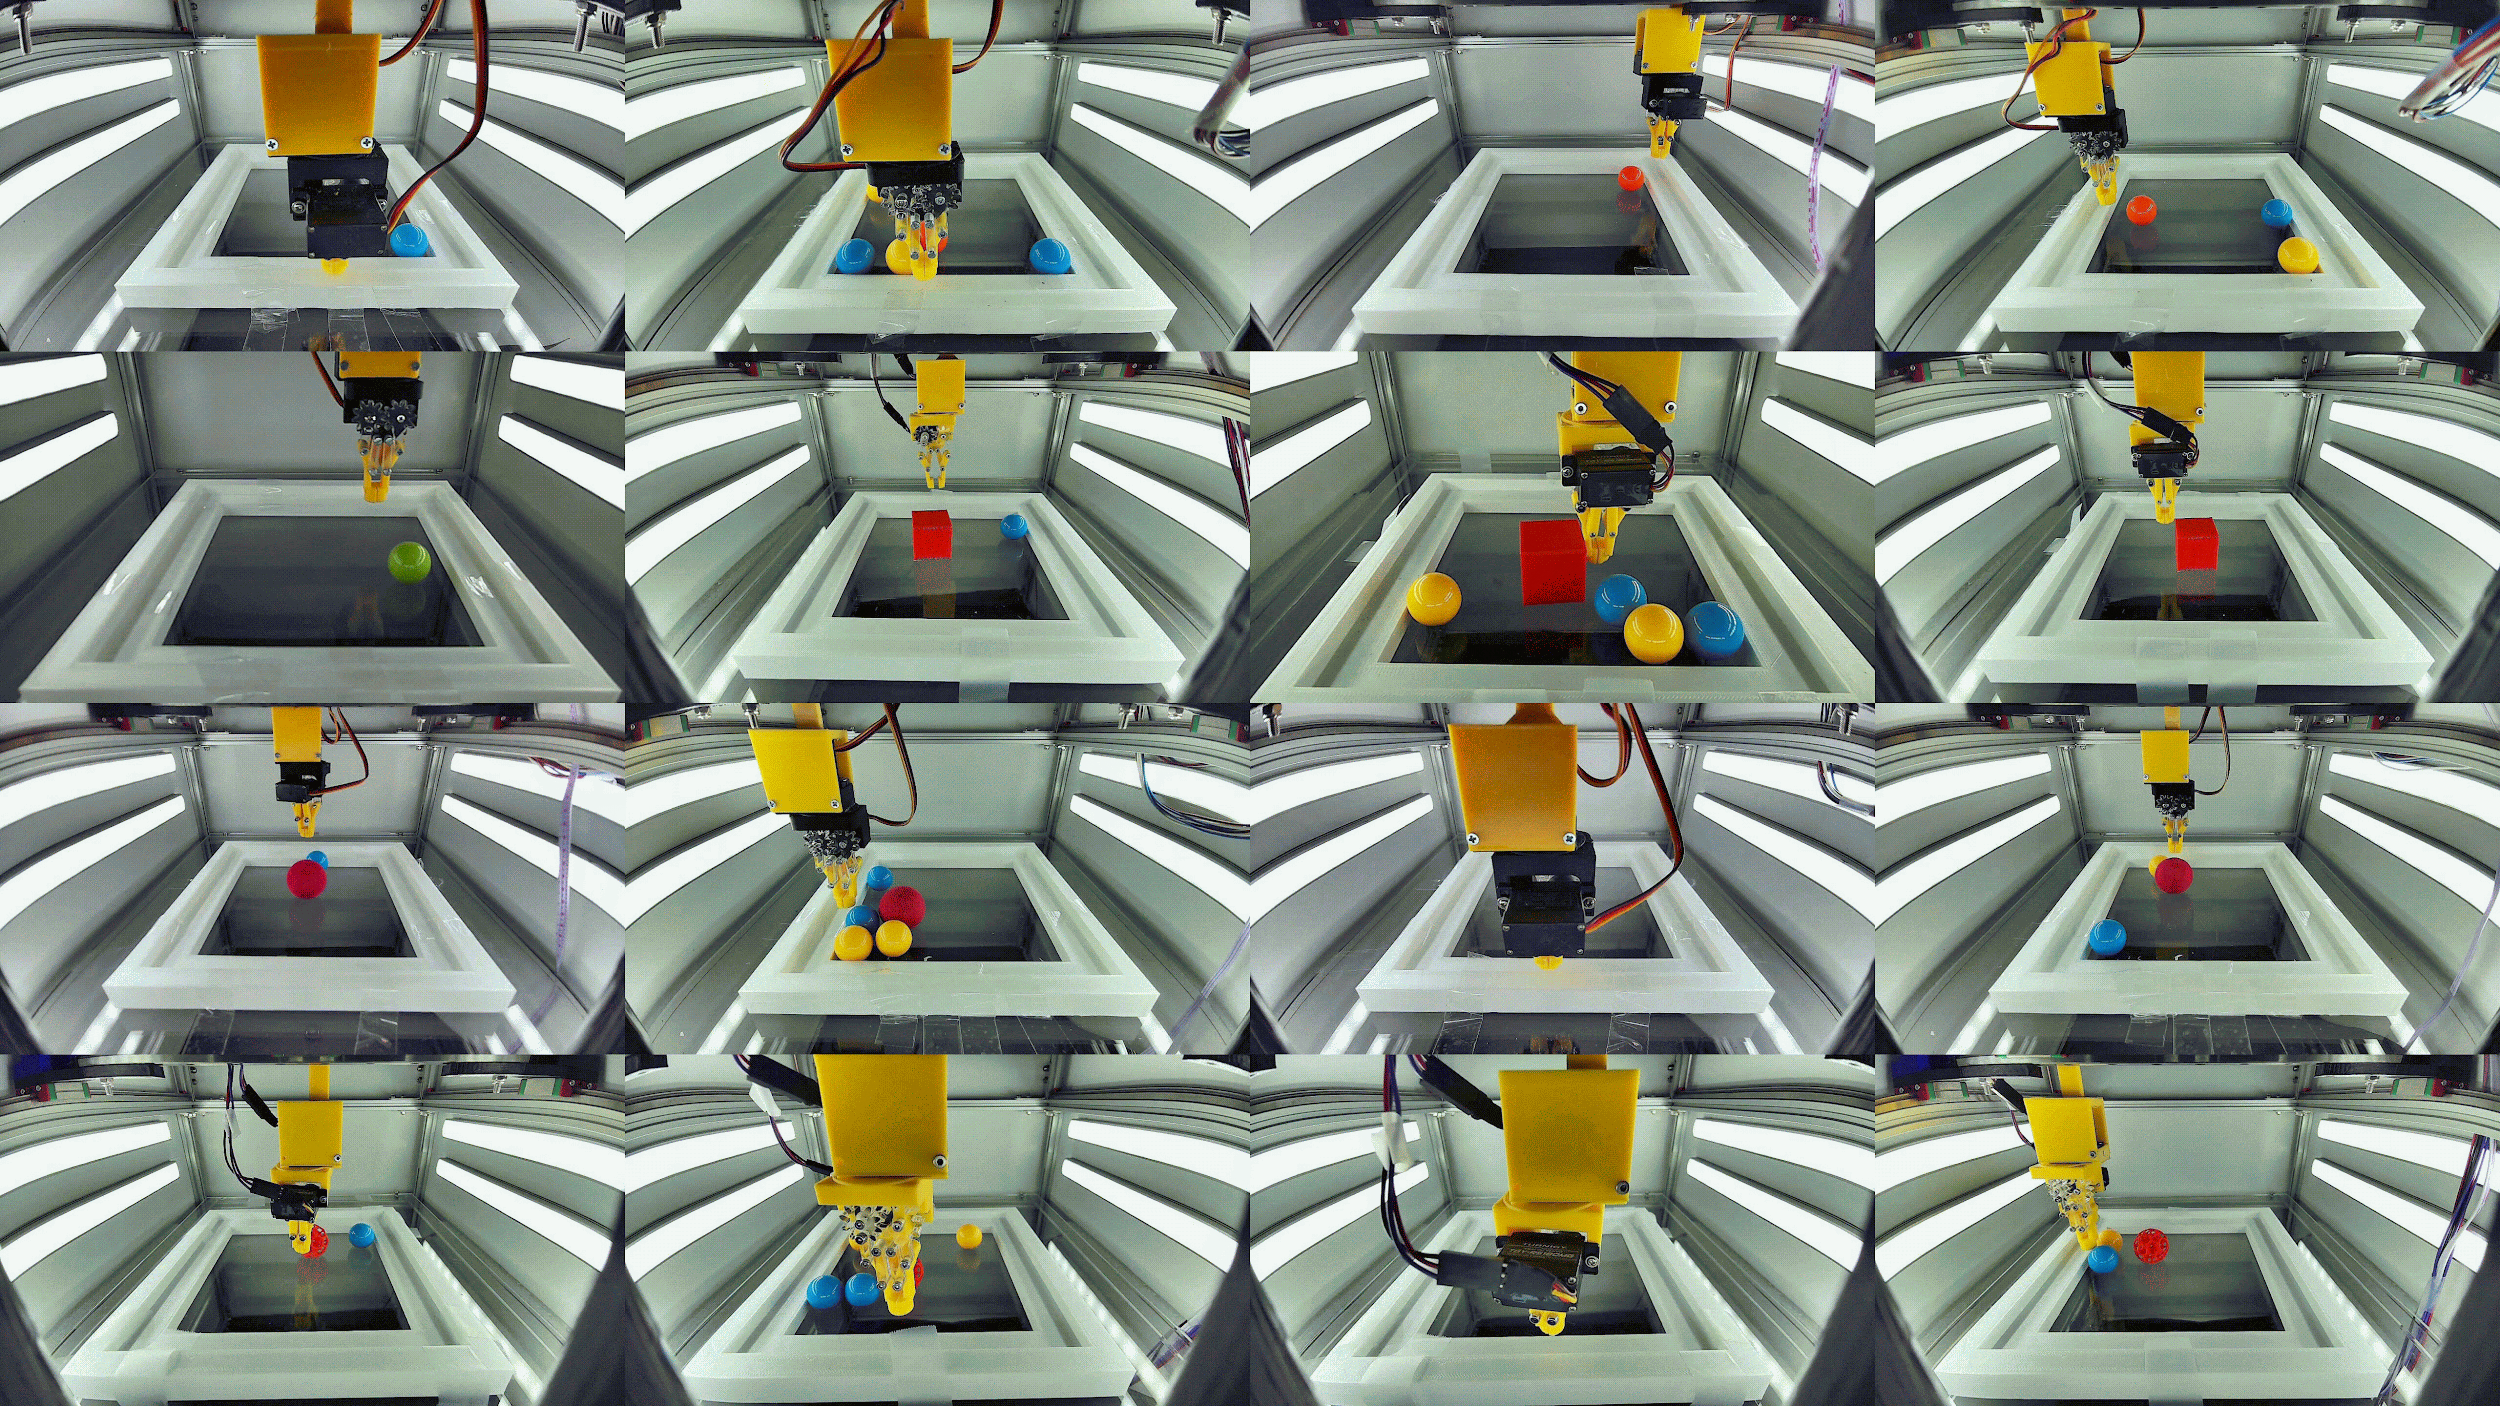
How Physics and Background Attributes Impact Video Transformers in Robotic Manipulation: A Case Study on Planar Pushing [Link] Shutong Jin, Ruiyu Wang, Muhammad Zahid and Florian T. Pokorny 2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS).
|
|
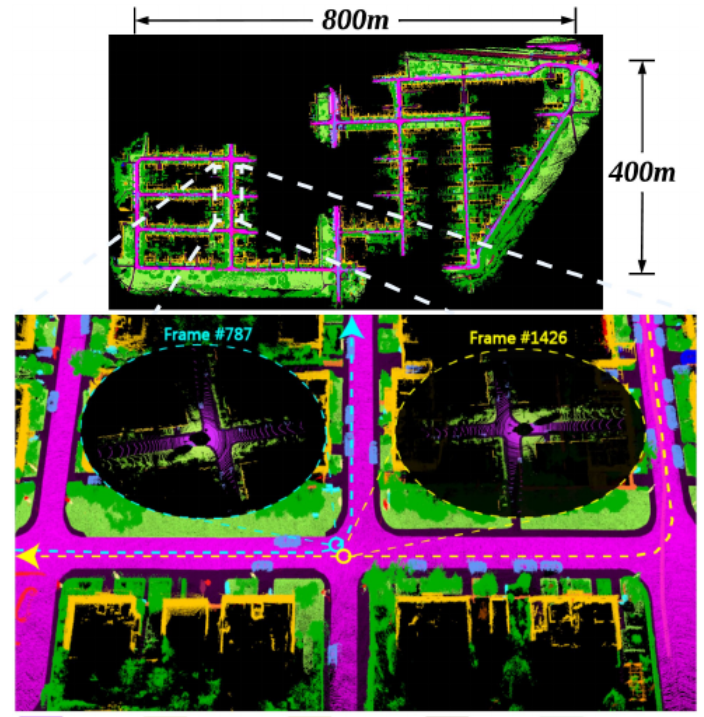
SectionKey: 3-D Semantic Point Cloud Descriptor for Place Recognition [Link] Shutong Jin*, Zhenyu Wu*, Chunyang Zhao, Jun Zhang, Guohao Peng and Danwei Wang 2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS).
|
Education
 |
PhD Candidate: KTH Royal Institute of Technology (Sweden)
|
 |
Visiting PhD Student: University of California, Berkeley (USA)
|
 |
Master: Nanyang Technological University (Singapore)
|
 |
Foundation Master: Ecole Centrale de Nantes (France)
|
 |
Bachelor: Wuhan University (China)
|